Every frame needs a box.
One day of teleoperation produces thousands of frames to label.
Send your recordings. Talo returns boxes, tracks, action segments and task descriptions in the schema your pipeline already reads.
01 Problem
One day of teleoperation produces thousands of frames to label.
Labels often arrive without the rules used or a record of what was checked.
Someone on the team rewrites the vendor's format before the pipeline can read it.
02 Sample
A demonstration clip labelled by Talo for this site; not customer work.
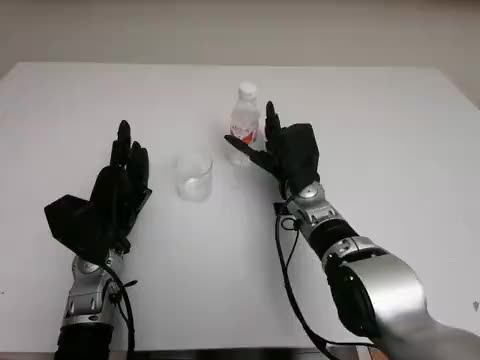
Labelled Self-checked
Task description
Send a short brief and we label a small batch of your own recordings this way, to criteria agreed before work starts.
Loading annotations…
Loading method…
Loading details…
03 Collection
Partners record to your tasks and environments; Talo labels and delivers each episode to the same criteria as your annotation work.
Egocentric
A head-mounted camera records both hands and the objects they handle, from the start of the task to the end. Each episode is labelled with object tracks, action segments and a task description.
Handheld gripper (UMI)
Wrist-camera video, with the gripper's position, orientation and opening width recorded in step with each frame. The fingers match the robot's, so a robot fitted with the same gripper can learn from the demonstrations directly.
Teleoperation
Video from the robot's own cameras, with its joint state and the operator's commands recorded in sync. The data comes from your hardware, so there is no gap between the body that demonstrates and the body that learns.
Annotation pilot
Start with a small batch of your own footage, labelled to agreed criteria, before any larger order. Don't paste raw data here; we arrange transfer after scoping.