Case study · Collection
A robotics startup gets household demonstrations from 30 homes it could not reach.
- episodes delivered
- 6,200
- homes, vs 1 test house
- 30
- from task list to last batch
- 8 wks
- of recordings failed intake, re-recorded
- 3.4%
The situation
Four prototype robots in one test house meant one kitchen, one set of plates and one kind of light. Policies that worked there failed elsewhere. It needed the same tasks recorded in many homes, without shipping robots.
What they asked for
- 20 tasks, from loading a dishwasher to folding towels, each recorded in at least 25 homes.
- Gripper demonstrations with fingers that match its robot's gripper, so the robot can learn from them directly.
- Every episode labelled to the same rules as its in-house data.
- Bad episodes caught before delivery, not after training.
What Talo delivered
4,100 head-camera episodes and 2,100 UMI gripper episodes, with the gripper's position, orientation and width aligned to each video frame at 60 Hz. Every episode has object tracks, action segments and a task description.
episode u-0918 · place_cup · home 17 · 0 to 8 sUMI
Video
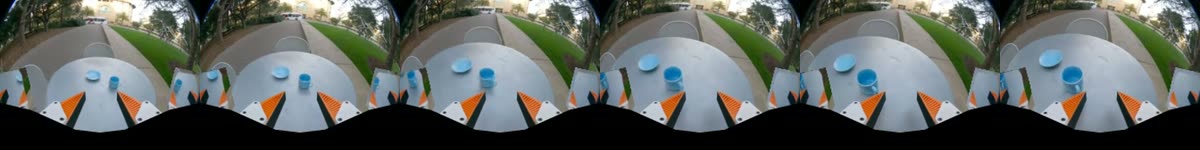
Gripper width
(open at top)
Segments
Segment boundaries line up with the gripper stream, so "grasp" ends where the width stops closing.
How it ran
- 1
Task list
Each of the 20 tasks was written as a short script: start state, end state and what may vary between homes.
- 2
Pilot week
3 tasks in 4 homes, 180 episodes. The startup loaded them into its training code to confirm the gripper data matched its robot.
- 3
Weekly batches
About 1,000 episodes a week. Each passed an intake checkA check on each new recording before labelling: camera clear, every data stream present, task completed., two labelling passes and a 10% auditA second annotator labels a sample of episodes on their own, and the two sets of labels are compared. by a second annotator.
Outcome
Every episode shipped with its rules and check log, so the startup could mix it with its own teleoperation data.
The automatic first pass, on a public dataset
Episode 0 of the open UMI cup dataset: a person carries a handheld gripper and places a cup on its saucer, outdoors. The gripper records its opening width with every frame. Move across the chart, pick a segment, or play the episode.
| Segment | Time |
|---|---|
| 0.0 to 20.1 s | |
| 20.1 to 20.3 s | |
| 20.3 to 30.5 s | |
| 30.5 to 30.8 s | |
| 30.8 to 39.9 s |
Gripper close-and-open cycles per episode, across all 1,447 episodes (19.4 hours)
Need demonstrations from places your robots cannot reach?
Ask about collection Next: lab annotation backlog →